JEE Main · Physics → Steady

System of Particles and Rotational Motion appeared 58 times across 3 years — 6.7% of Physics. This question is from Uniform Circular Motion and Dynamics.

Year 2026 2025 2024 Total
Questions 20 27 11 58

If L and P represent the angular momentum and linear momentum respectively of a particle of mass 'm' having position vector r = a( i ω t + j ω t). The direction of force is

Solution & Explanation

Related Formula

Acceleration vector equation via secondary derivation:

a = d² rdt²

Force equation:

F = m a
Core Logic

Given position tracking trace:

r = a( i ω t + j ω t)

Velocity vector v:

v = d rdt = aω(- i ω t + j ω t)
Step 1: Differentiate to find Acceleration
a = d vdt = aω²(- i ω t - j ω t) a = -ω² [ a( i ω t + j ω t) ] = -ω² r
Step 2: Establish Force Direction
F = m a = -mω² r

The minus sign indicates the net centripetal pulling force aligns explicitly opposite to the direction of r.

Pattern Recognition

The expression describes a standard uniform circular motion profile. In circular configurations, acceleration and centripetal forces point radially inward, directly opposing the outbound position tracker vector.

Chapter Mix

Class 11 Physics: Kinematics Class 11 Physics: System of Particles and Rotational Motion

More System of Particles and Rotational Motion Previous-Year Questions — Page 10

Q17 jee_main_2025_28_jan_evening Torque and Equilibrium
A uniform rod of mass 250g having length 100cm is balanced on a sharp edge at 40cm mark[cite: 150, 151]. A mass of 400g is suspended at 10cm mark. To maintain the balance of the rod, the mass to be suspended at 90cm mark, is [cite: 154, 156]
  • A. 300g
  • B. 190g
  • C. 200g
  • D. 290g

Solution

Related Formula

For rotational equilibrium, the \sum of all counter-clockwise torques about the pivot point must exactly balance the \sum of all clockwise torques:

Σ τpivot = 0 Σ (mᵢ · g · xᵢ) = 0
Core Logic

The rod is uniform, meaning its mass (250 g) acts exactly at its geometric center of mass, the 50 cm mark[cite: 150, 151]. Let the pivot point be the sharp edge at the 40 cm mark .

Calculate the relative lever arms from the pivot [cite: 775, 776, 777]:

  • 400 g mass at 10 cm mark: lever arm = 40 - 10 = 30 cm (counter-clockwise)
  • 250 g rod mass at 50 cm mark: lever arm = 50 - 40 = 10 cm (clockwise)
  • Unknown mass M at 90 cm mark: lever arm = 90 - 40 = 50 cm (clockwise)
  • Setting up the torque balance equation:

400 × 30 = (250 × 10) + (M × 50) 12000 = 2500 + 50M 50M = 9500 M = (9500)/(50) = 190 g
Step 1: Visual Context

The structural layout of forces acting on the balanced rod system is shown below:

Torque and Equilibrium balancing diagram for Q17

Pattern Recognition

Never forget to include the weight of a uniform rod itself in equilibrium equations. It is a common oversight to omit the rod's mass, which always acts at its geometric center.

Chapter Mix

Class 11 Physics: System of Particles and Rotational Motion
Q jee_main_2025_29_jan_morning Torque
The coordinates of a particle with respect to origin in a given reference frame is (1, 1, 1) meters. If a force of F = i - j + k acts on the particle, then the magnitude of torque (with respect to origin) in z -direction is
Numerical Answer. Answer: 2 to 2

Solution

Related Formula
τ = r × F
Core Logic

Given position vector r = i + j + k and force F = i - j + k:

τ = | arrayccc i & j & k 1 & 1 & 1 1 & -1 & 1 array |
Step 1: Isolate z-component
τz = k(1(-1) - 1(1)) = -2 k

The absolute magnitude of the torque component in the z-direction equals 2 ~N · m.

Chapter Mix

Class 11 Physics: System of Particles and Rotational Motion

Q jee_main_2024_01_february_morning Centre of Mass
The identical spheres each of mass 2M are placed at the corners of a right angled triangle with mutually perpendicular sides equal to 4~m each. Taking point of intersection of these two sides as origin, the magnitude of position vector of the centre of mass of the system is 4√(2)x, where the value of x is ______.
Numerical Answer. Answer: 3 to 3

Solution

Related Formula

Position vector of the Centre of Mass (COM):

rCOM = m₁ r₁ + m₂ r₂ + m₃ r₃m₁ + m₂ + m₃
Core Logic

Assign coordinates to the three masses (m₁=m₂=m₃=2M):

  • Origin mass: r₁ = 0 i + 0 j
  • X-axis mass: r₂ = 4 i + 0 j
  • Y-axis mass: r₃ = 0 i + 4 j
  • Substitute these into the COM formula:

rCOM = 2M(0) + 2M(4 i) + 2M(4 j)2M + 2M + 2M = 8M i + 8M j6M = (4)/(3) i + (4)/(3) j
Step 1: Calculate Position Vector Magnitude
| rCOM| = √(((4)/(3))² + ((4)/(3))²) = 4√(2)3

Matching this directly with the given template 4√(2)x shows that x = 3.

Pattern Recognition

Since the mass layout is completely symmetric along both right-angle legs, the COM coordinates are identical (xCOM = yCOM).

Chapter Mix

Class 11 Physics: System of Particles and Rotational Motion

Q60 jee_main_2024_29_january_evening Angular Momentum of a Particle
A body of mass 5 kg moving with a uniform speed 3√(2) ms⁻¹ in X–Y plane along the line y = x + 4. The angular momentum of the particle about the origin will be ______ kg m²s⁻¹.
Numerical Answer. Answer: 60 to 60

Solution

Related Formula

The magnitude of the angular momentum L of a particle of mass m moving with velocity v is:

L = m v d

where:

  • d is the perpendicular distance from the axis of rotation (origin) to the line of motion of the particle.
Core Logic

Given parameters:

  • Mass, m = 5 kg
  • Velocity, v = 3√(2) ms⁻¹
  • Line of motion: y = x + 4 x - y + 4 = 0
Step 1: Calculate Perpendicular Distance

The perpendicular distance d from the origin (0,0) to the line Ax + By + C = 0 is:

d = |A(0) + B(0) + C|√(A² + B²)

For the line x - y + 4 = 0:

d = |4|√(1² + (-1)²) = 4√(2) = 2√(2) m
Step 2: Calculate Angular Momentum

Substitute the values into the angular momentum formula:

L = m v d

L = 5 kg × (3√(2) ms⁻¹) × (2√(2) m) L = 5 × 3 × 4 = 60 kg m²s⁻¹

Thus, the angular momentum of the particle about the origin is 60 kg m²s⁻¹.

Pattern Recognition

Instead of complicated vector cross products, find the perpendicular distance of the straight line from the origin using standard coordinate geometry. L = mvd is extremely fast and reliable.

Chapter Mix

Class 11 Physics: System of Particles and Rotational Motion

Q jee_main_2024_27_jan_morning Moment of Inertia
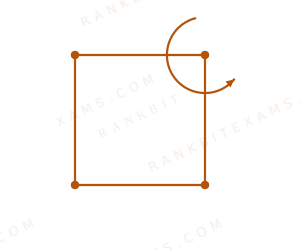
Four particles each of mass 1 kg are placed at four corners of a square of side 2 m. The moment of inertia of the system about an axis perpendicular to its plane and passing through one of its vertices is ______ kg ². {{IMG}}
Moment of Inertia
Moment of Inertia
Numerical Answer. Answer: 16 to 16

Solution

Related Formula
I = Σ mᵢ rᵢ²
Core Logic

Let the axis pass through vertex 1. Evaluate distances (r) for each corner particle:

  • Particle at vertex 1: r₁ = 0
  • Particle at adjacent vertex 2: r₂ = a
  • Particle at adjacent vertex 4: r₄ = a
  • Particle at diagonally opposite vertex 3: r₃ = √(2)a
Step 1: Set up substitution formula
I = m(0)² + m(a)² + m(a)² + m(√(2)a)² I = ma² + ma² + 2ma² = 4ma²
Step 2: Numeric Evaluation

Substitute m = 1 kg and side length a = 2 m:

I = 4 × 1 × (2)² = 4 × 4 = 16 kg ²
Pattern Recognition

For a standard planar configuration system, total orthogonal moment components map predictably via basic summation configurations matching 4ma² exactly.

Chapter Mix

Class 11 Physics: System of Particles and Rotational Motion

More System of Particles and Rotational Motion Questions — jee_main_2025_04_april_morning

Practice all System of Particles and Rotational Motion previous-year questions →

Rankbit System
JEE Physics: Waves (+15.5%) | Electrostatics: Concentric Shells (-29.7%) | Modern Physics: Photoelectric Clones (+34.2%) | Mathematics: Definite Integrals (+18.1%) | Chemistry: Coordination Splitting (-11.4%) | JEE Physics: Waves (+15.5%) | Electrostatics: Concentric Shells (-29.7%) | Modern Physics: Photoelectric Clones (+34.2%) | Mathematics: Definite Integrals (+18.1%) | Chemistry: Coordination Splitting (-11.4%)