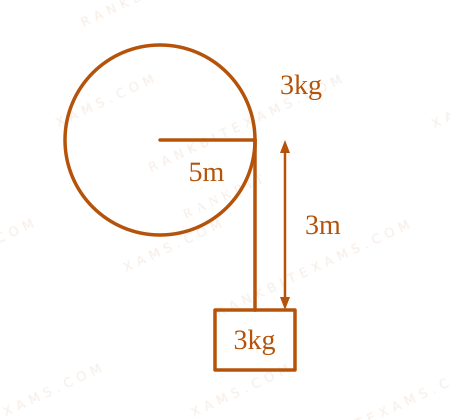
A fly wheel having mass 3 kg$3 \text{ kg}$ and radius 5 m$5 \text{ m}$ is free to rotate about a horizontal axis. A string having negligible mass is wound around the wheel and the loose end of the string is connected to a 3 kg$3 \text{ kg}$ mass. The mass is kept at rest initially and released. Kinetic energy of the wheel when the mass descends by 3 m$3 \text{ m}$ is ____ J. (g = 10 m/s²$g = 10 \text{ m/s}^{2}$ )
Solution for Rotation about Fixed Axis
By conservation of mechanical energy, the loss in gravitational potential energy of the descending mass equals the gain in kinetic energy of the block and the rotational kinetic energy of the flywheel.
mg h = (1)/(2) I ω² + (1)/(2) m v²$$mg h = \frac{1}{2} I \omega^2 + \frac{1}{2} m v^2$$
Step 1: Relate Velocity and Angular Velocity
Since the string does not slip, the linear velocity v$v$ of the mass is related to the angular velocity ω$\omega$ of the wheel by:
v = ω R ⇒ ω = (v)/(R)$$v = \omega R \Rightarrow \omega = \frac{v}{R}$$
Step 2: Energy Conservation
The flywheel is treated as a solid disc/cylinder (from the I = mR²/2$I = mR^2/2$ usage in the solution):
mg h = (1)/(2) ((M R²)/(2)) ω² + (1)/(2) m v²$$mg h = \frac{1}{2} \left(\frac{M R^2}{2}\right) \omega^2 + \frac{1}{2} m v^2$$
Given M = 3 kg$M = 3 \text{ kg}$ (wheel), m = 3 kg$m = 3 \text{ kg}$ (block), h = 3 m$h = 3 \text{ m}$.
Notice that the solution text specifies the flywheel mass as m$m$ and block mass also as m$m$, both being 3 kg$3\text{ kg}$. Let's follow the PDF exactly:
mg × 3 = (1)/(4) m v² + (1)/(2) m v²$$mg \times 3 = \frac{1}{4} m v^2 + \frac{1}{2} m v^2$$3mg = (3)/(4) m v²$$3mg = \frac{3}{4} m v^2$$v² = 4g = 4 × 10 = 40 (m/s)²$$v^2 = 4g = 4 \times 10 = 40 \text{ (m/s)}^2$$
Step 4: Calculate Kinetic Energy of Flywheel
K.E.wheel = (1)/(2) I ω² = (1)/(4) m v²$$K.E._{\text{wheel}} = \frac{1}{2} I \omega^2 = \frac{1}{4} m v^2$$K.E.wheel = (1)/(4) × 3 × 40 = 30 J$$K.E._{\text{wheel}} = \frac{1}{4} \times 3 \times 40 = 30 \text{ J}$$
Pattern Recognition
For a mass pulling a wheel of identical mass (disc), the total K.E.$K.E.$ is split between translational (1/2 mv²$1/2 mv^2$) and rotational (1/4 mv²$1/4 mv^2$). Rotational gets exactly 1/3$1/3$ of the total potential energy lost, 30 J$30\text{ J}$ out of 90 J$90\text{ J}$ total.
Chapter Mix
Class 11 Physics: Systems of Particles and Rotational Motion
Class 11 Physics: Work, Energy and Power
Keywords:#fly wheel having mass 3 kg#JEE Main 2026 Evening Q50#Systems of Particles and Rotational Motion JEE Main 2026#Rotation about Fixed Axis JEE Main 2026
More Systems of Particles and Rotational Motion Previous-Year Questions — Page 10
Q17jee_main_2025_28_jan_eveningTorque and Equilibrium
A uniform rod of mass 250g$250\mathrm{g}$ having length 100cm$100\mathrm{cm}$ is balanced on a sharp edge at 40cm$40\mathrm{cm}$ mark[cite: 150, 151]. A mass of 400g$400\mathrm{g}$ is suspended at 10cm$10\mathrm{cm}$ mark. To maintain the balance of the rod, the mass to be suspended at 90cm$90\mathrm{cm}$ mark, is [cite: 154, 156]
A.300g$300\mathrm{g}$
B.190g$190\mathrm{g}$
C.200g$200\mathrm{g}$
D.290g$290\mathrm{g}$
Solution
Related Formula
For rotational equilibrium, the \sum of all counter-clockwise torques about the pivot point must exactly balance the \sum of all clockwise torques:
The rod is uniform, meaning its mass (250 g$250\text{ g}$) acts exactly at its geometric center of mass, the 50 cm$50\text{ cm}$ mark[cite: 150, 151]. Let the pivot point be the sharp edge at the 40 cm$40\text{ cm}$ mark .
Calculate the relative lever arms from the pivot [cite: 775, 776, 777]:
400 g$400\text{ g}$ mass at 10 cm$10\text{ cm}$ mark: lever arm = 40 - 10 = 30 cm$= 40 - 10 = 30\text{ cm}$ (counter-clockwise)
250 g$250\text{ g}$ rod mass at 50 cm$50\text{ cm}$ mark: lever arm = 50 - 40 = 10 cm$= 50 - 40 = 10\text{ cm}$ (clockwise)
Unknown mass M$M$ at 90 cm$90\text{ cm}$ mark: lever arm = 90 - 40 = 50 cm$= 90 - 40 = 50\text{ cm}$ (clockwise)
The structural layout of forces acting on the balanced rod system is shown below:
Torque and Equilibrium balancing diagram for Q17
Pattern Recognition
Never forget to include the weight of a uniform rod itself in equilibrium equations. It is a common oversight to omit the rod's mass, which always acts at its geometric center.
Chapter Mix
Class 11 Physics: System of Particles and Rotational Motion
Qjee_main_2025_29_jan_morningTorque
The coordinates of a particle with respect to origin in a given reference frame is (1, 1, 1) meters. If a force of F = i - j + k$\vec{\mathrm{F}} = \hat{\mathrm{i}} -\hat{\mathrm{j}} +\hat{\mathrm{k}}$ acts on the particle, then the magnitude of torque (with respect to origin) in z$z$ -direction is
Numerical Answer.Answer: 2 to 2
Solution
Related Formula
τ = r × F$$\vec{\tau} = \vec{r} \times \vec{F}$$
Core Logic
Given position vector r = i + j + k$\vec{r} = \hat{i} + \hat{j} + \hat{k}$ and force F = i - j + k$\vec{F} = \hat{i} - \hat{j} + \hat{k}$:
The absolute magnitude of the torque component in the z$z$-direction equals 2 ~N · m$2 \mathrm{~N \cdot m}$.
Chapter Mix
Class 11 Physics: System of Particles and Rotational Motion
Qjee_main_2024_01_february_morningCentre of Mass
The identical spheres each of mass 2M are placed at the corners of a right angled triangle with mutually perpendicular sides equal to 4~m$4\mathrm{~m}$ each. Taking point of intersection of these two sides as origin, the magnitude of position vector of the centre of mass of the system is 4√(2)x$\frac{4\sqrt{2}}{x}$, where the value of x$x$ is ______.
Matching this directly with the given template 4√(2)x$\frac{4\sqrt{2}}{x}$ shows that x = 3$x = 3$.
Pattern Recognition
Since the mass layout is completely symmetric along both right-angle legs, the COM coordinates are identical (xCOM = yCOM$x_{\text{COM}} = y_{\text{COM}}$).
Chapter Mix
Class 11 Physics: System of Particles and Rotational Motion
Q60jee_main_2024_29_january_eveningAngular Momentum of a Particle
A body of mass 5 kg$5\text{ kg}$ moving with a uniform speed 3√(2) ms⁻¹$3\sqrt{2}\text{ ms}^{-1}$ in X–Y plane along the line y = x + 4$y = x + 4$. The angular momentum of the particle about the origin will be ______ kg m²s⁻¹$\text{kg m}^2\text{s}^{-1}$.
Numerical Answer.Answer: 60 to 60
Solution
Related Formula
The magnitude of the angular momentum L$L$ of a particle of mass m$m$ moving with velocity v$v$ is:
L = m v d$L = m v d$
where:
d$d$ is the perpendicular distance from the axis of rotation (origin) to the line of motion of the particle.
Core Logic
Given parameters:
Mass, m = 5 kg$m = 5\text{ kg}$
Velocity, v = 3√(2) ms⁻¹$v = 3\sqrt{2}\text{ ms}^{-1}$
Line of motion: y = x + 4 x - y + 4 = 0$y = x + 4 \implies x - y + 4 = 0$
Step 1: Calculate Perpendicular Distance
The perpendicular distance d$d$ from the origin (0,0)$(0,0)$ to the line Ax + By + C = 0$Ax + By + C = 0$ is:
Instead of complicated vector cross products, find the perpendicular distance of the straight line from the origin using standard coordinate geometry. L = mvd$L = mvd$ is extremely fast and reliable.
Chapter Mix
Class 11 Physics: System of Particles and Rotational Motion
Qjee_main_2024_27_jan_morningMoment of Inertia
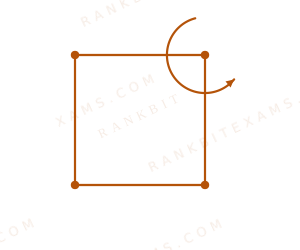
Four particles each of mass 1 kg$1\text{ kg}$ are placed at four corners of a square of side 2 m$2\text{ m}$. The moment of inertia of the system about an axis perpendicular to its plane and passing through one of its vertices is ______ kg ²$\text{kg}\cdot\text{m}^{2}$.
{{IMG}}
Moment of Inertia
Numerical Answer.Answer: 16 to 16
Solution
Related Formula
I = Σ mᵢ rᵢ²$$I = \sum m_i r_i^2$$
Core Logic
Let the axis pass through vertex 1. Evaluate distances (r$r$) for each corner particle:
For a standard planar configuration system, total orthogonal moment components map predictably via basic summation configurations matching 4ma²$4ma^2$ exactly.
Chapter Mix
Class 11 Physics: System of Particles and Rotational Motion
More Systems of Particles and Rotational Motion Questions — jee_main_2026_28_january_evening
Practice past-year questions one chapter at a time. Pick an exam → subject → chapter and get every PYQ for that topic — pulled together from all past papers — with the chapter's key formulas alongside.